Move by teleop.
Interact natively.
A step toward native interaction for humanoid robots.
RESEARCH TEAM
* Equal contribution
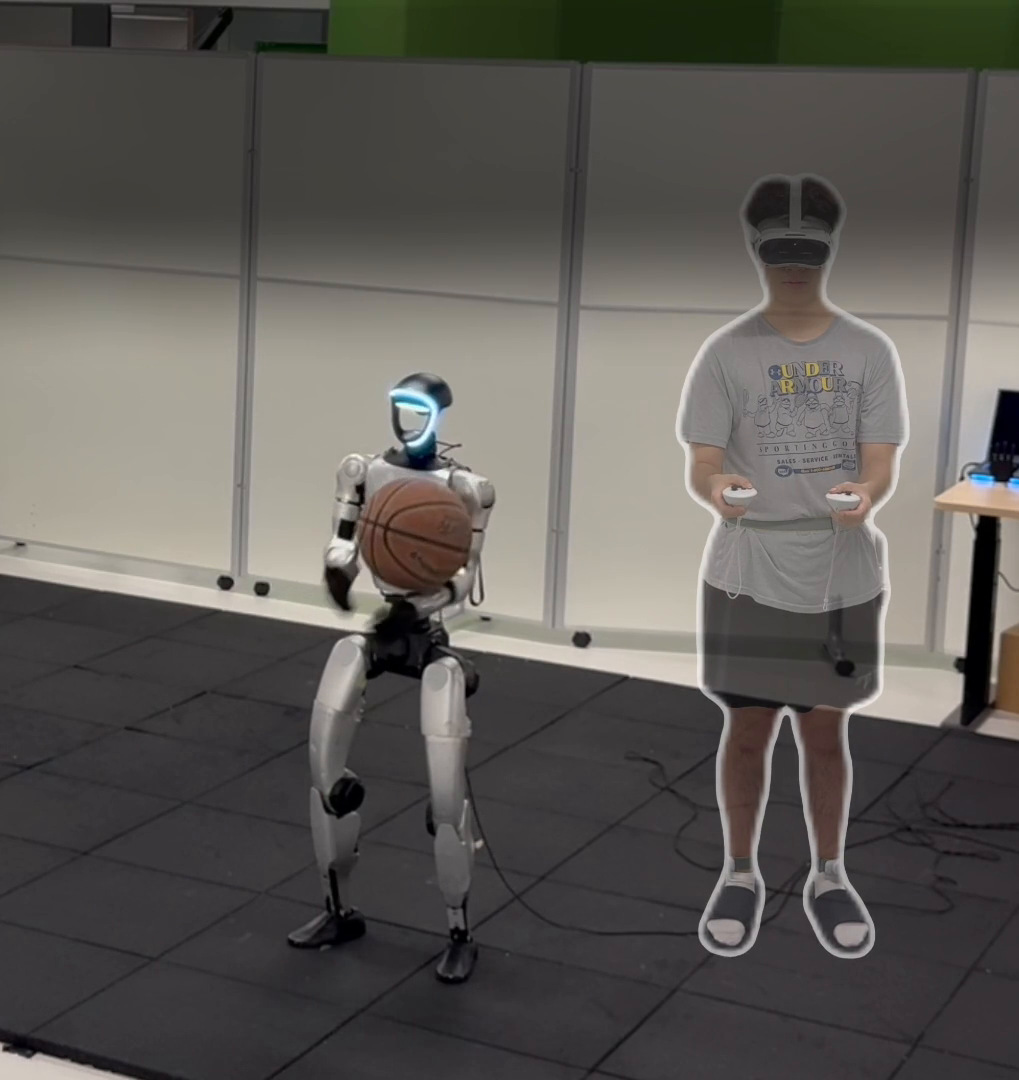
01 — THE FILM
See interaction in motion.
Real-world humanoid interaction,
one moment at a time.
02 — THE IDEA
Movement is only
half the story.
Humanoids have learned how to move.
Now, how do they interact?
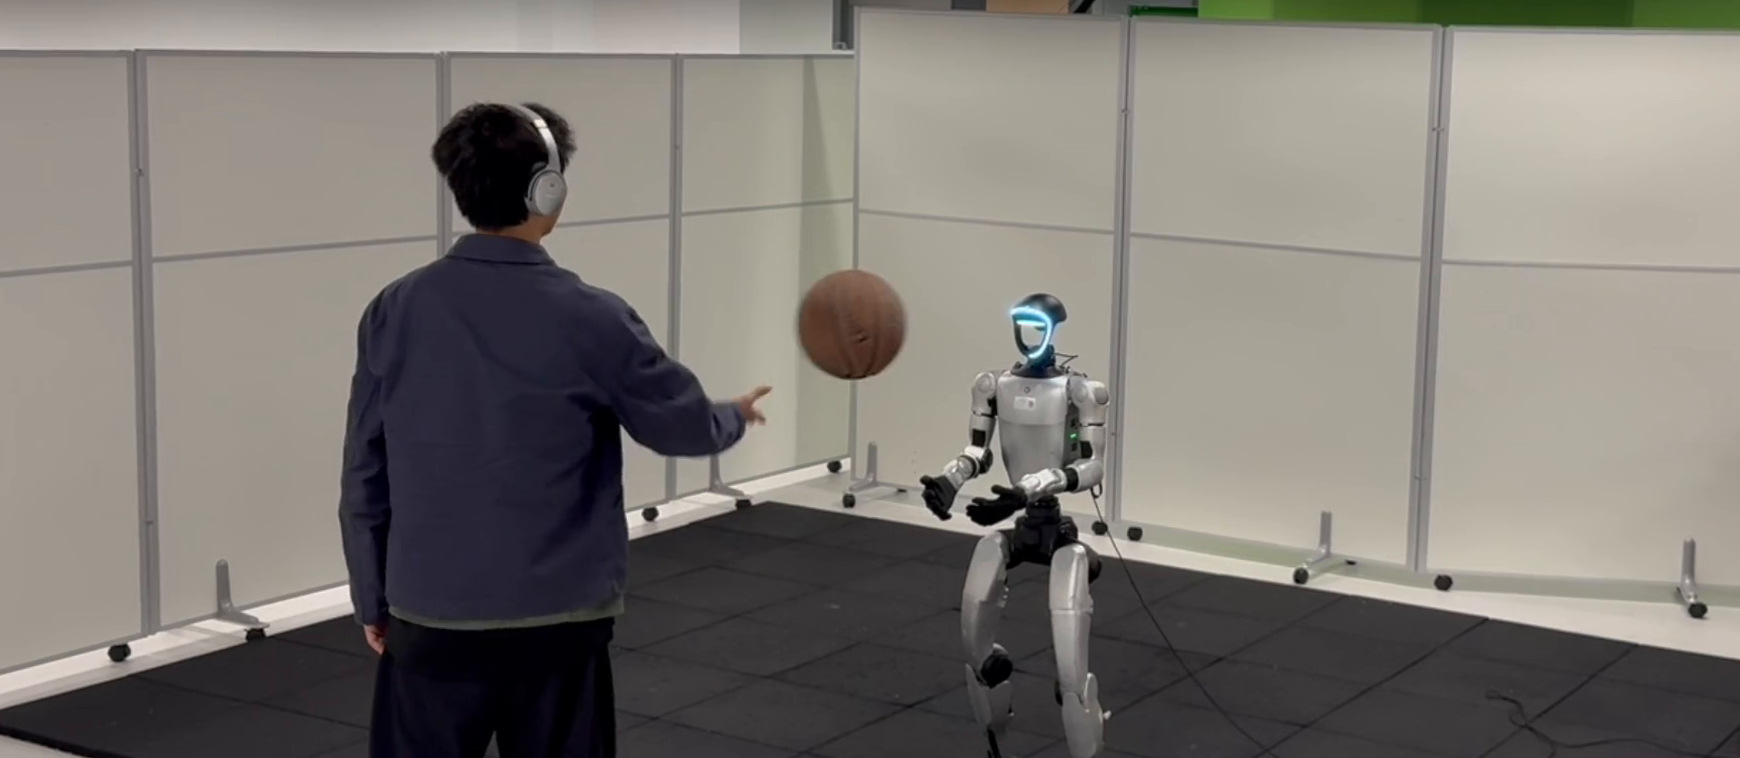
Beautiful whole-body motion is not the same as reliable physical interaction. The difficult moments happen at contact: approaching an object, securing it, keeping hold, adapting to changes, and letting go.
We envision interaction as a native capability of humanoid robots—so people can guide movement without having to micromanage every physical contact. LIFe is one step in that direction.
03 — THE MOMENTS
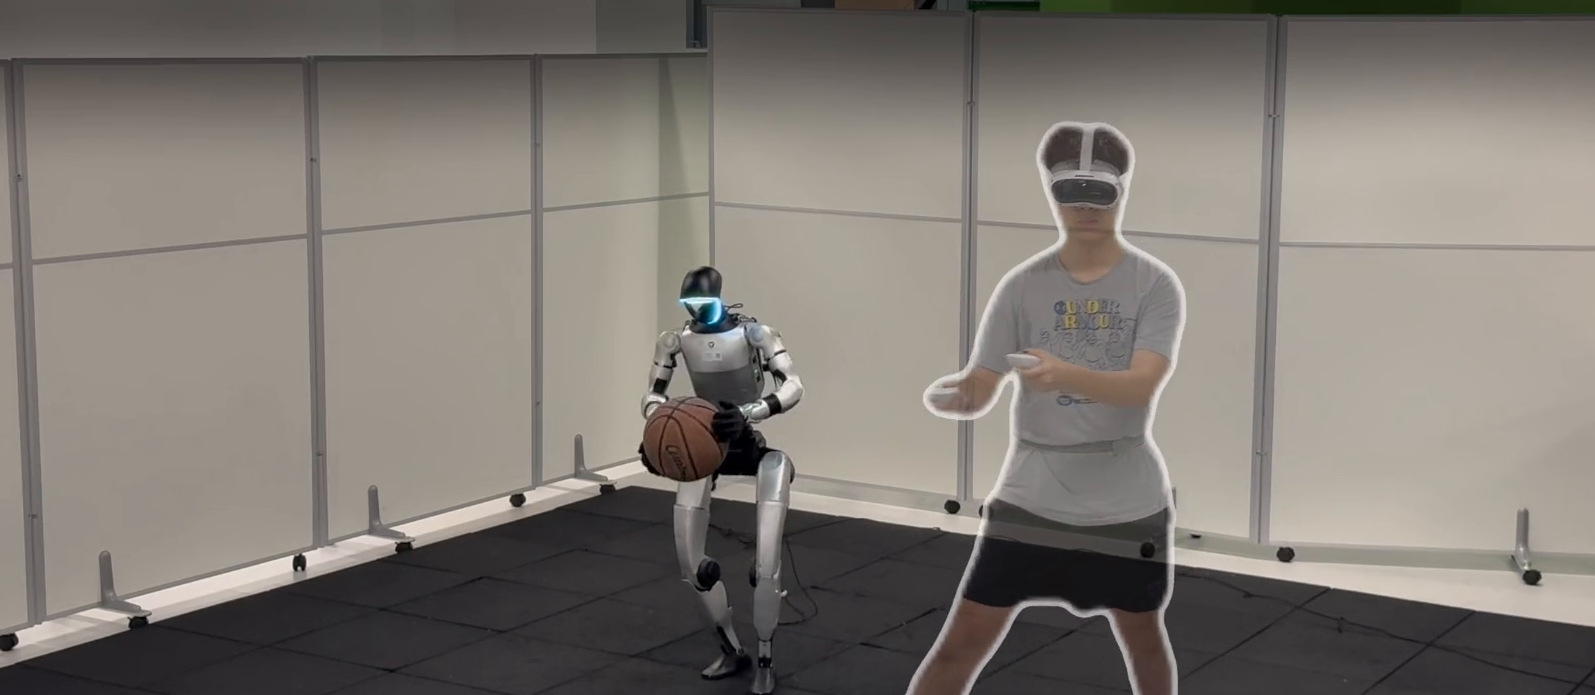
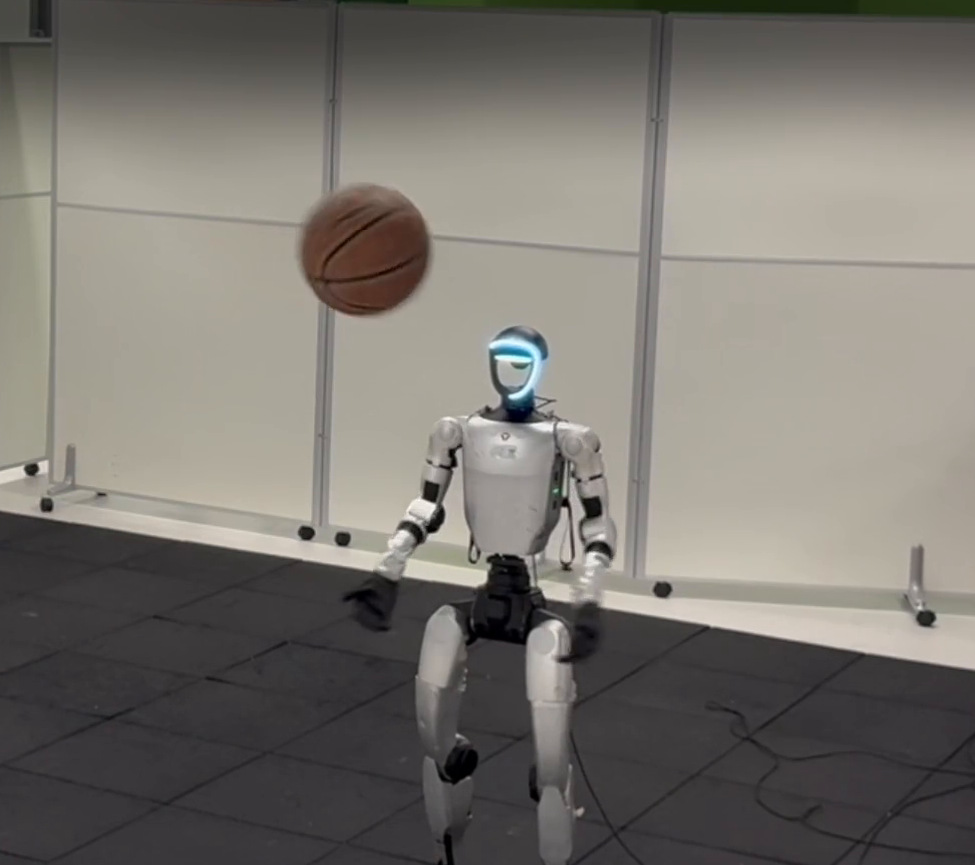
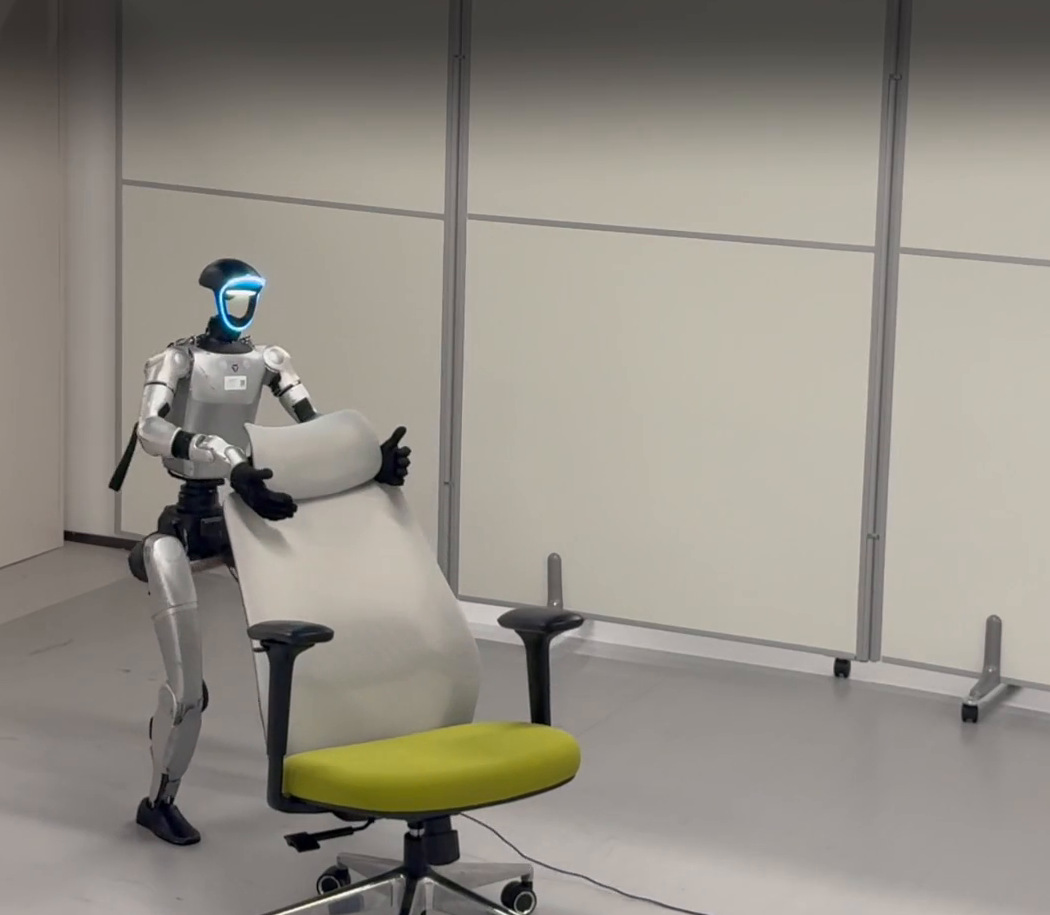
Beyond a single trick.
A glimpse of the interactions
shown in the film.
THE DIRECTION IS CLEAR
Less micromanaging.
More interaction.
LIFe is an exploration of the next layer of humanoid intelligence: not just moving through the world, but physically engaging with it.
Replay the film